Research
* equal contribution ✉ corresponding author
Publications

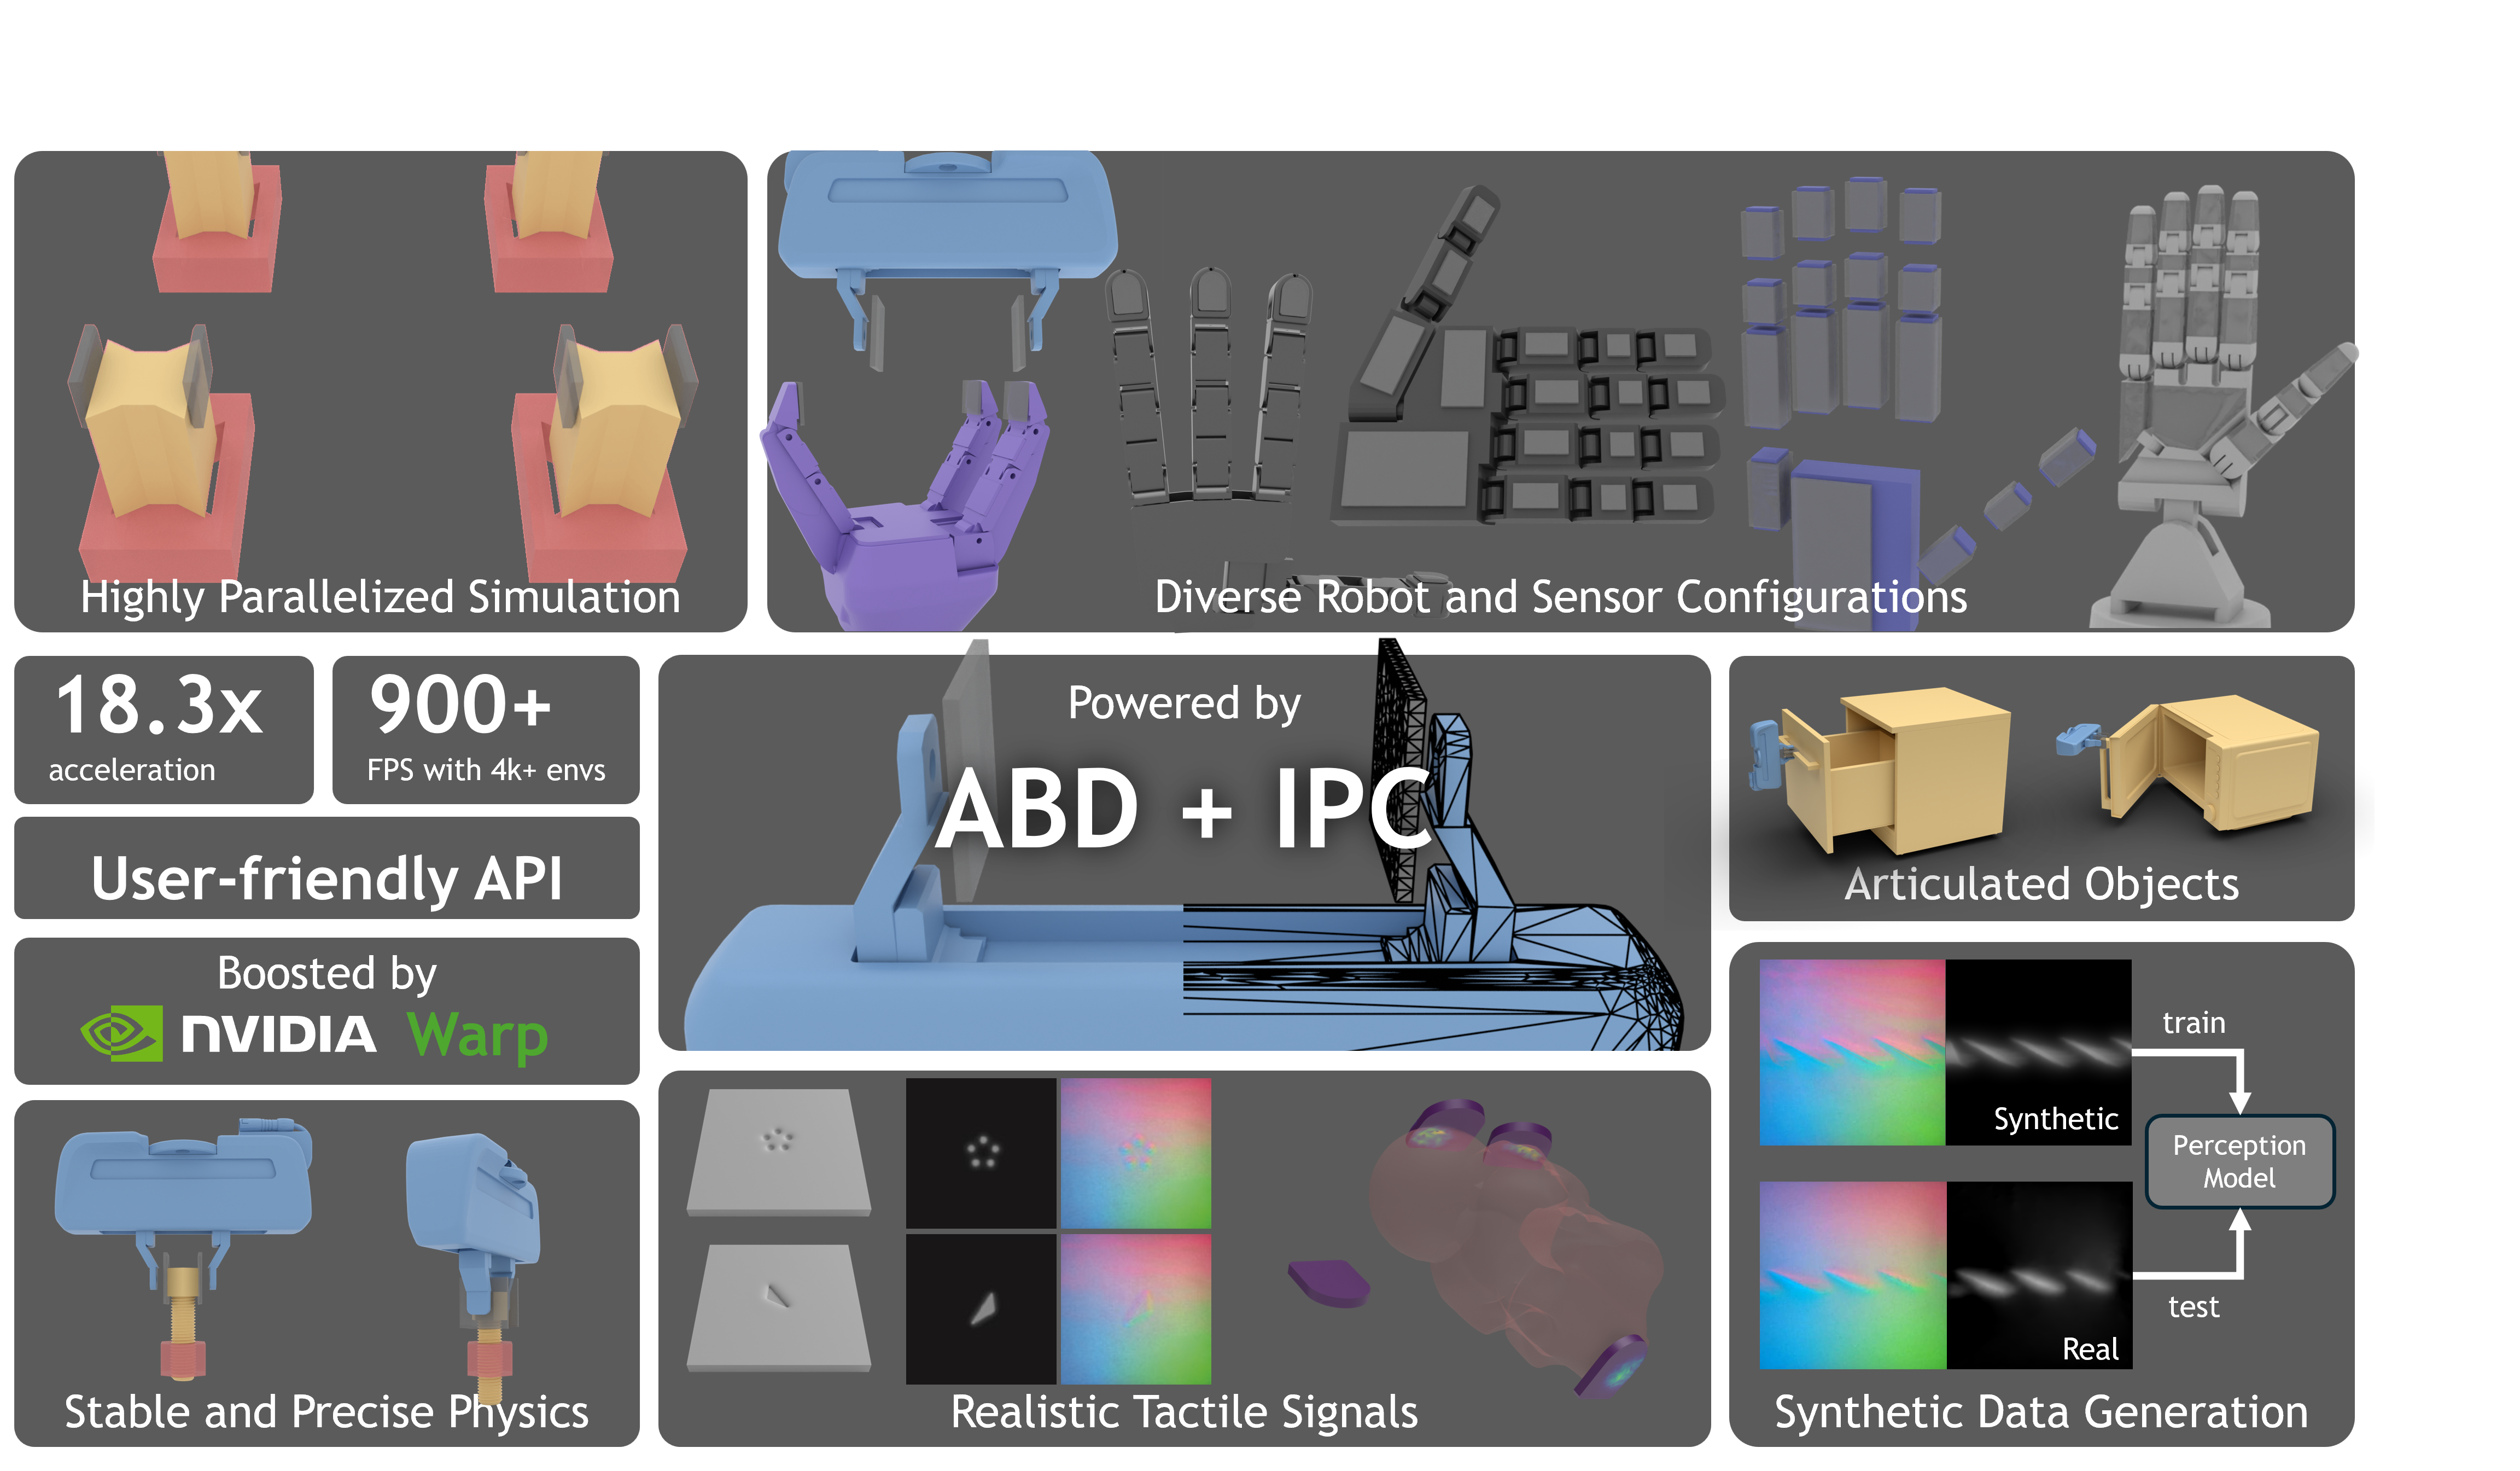
Taccel: Scaling Up Vision-based Tactile Robotics via High-performance GPU Simulation
Taccel is a high-performance GPU-based simulator, combining ABD and IPC, for simulating robots with vision-based tactile sensors.
Paper
Code
Website / Docs
Video
Mention in NVIDIA Tech Blog
Mention in Linux Foundation
Mention in GTC Paris
 27 citations
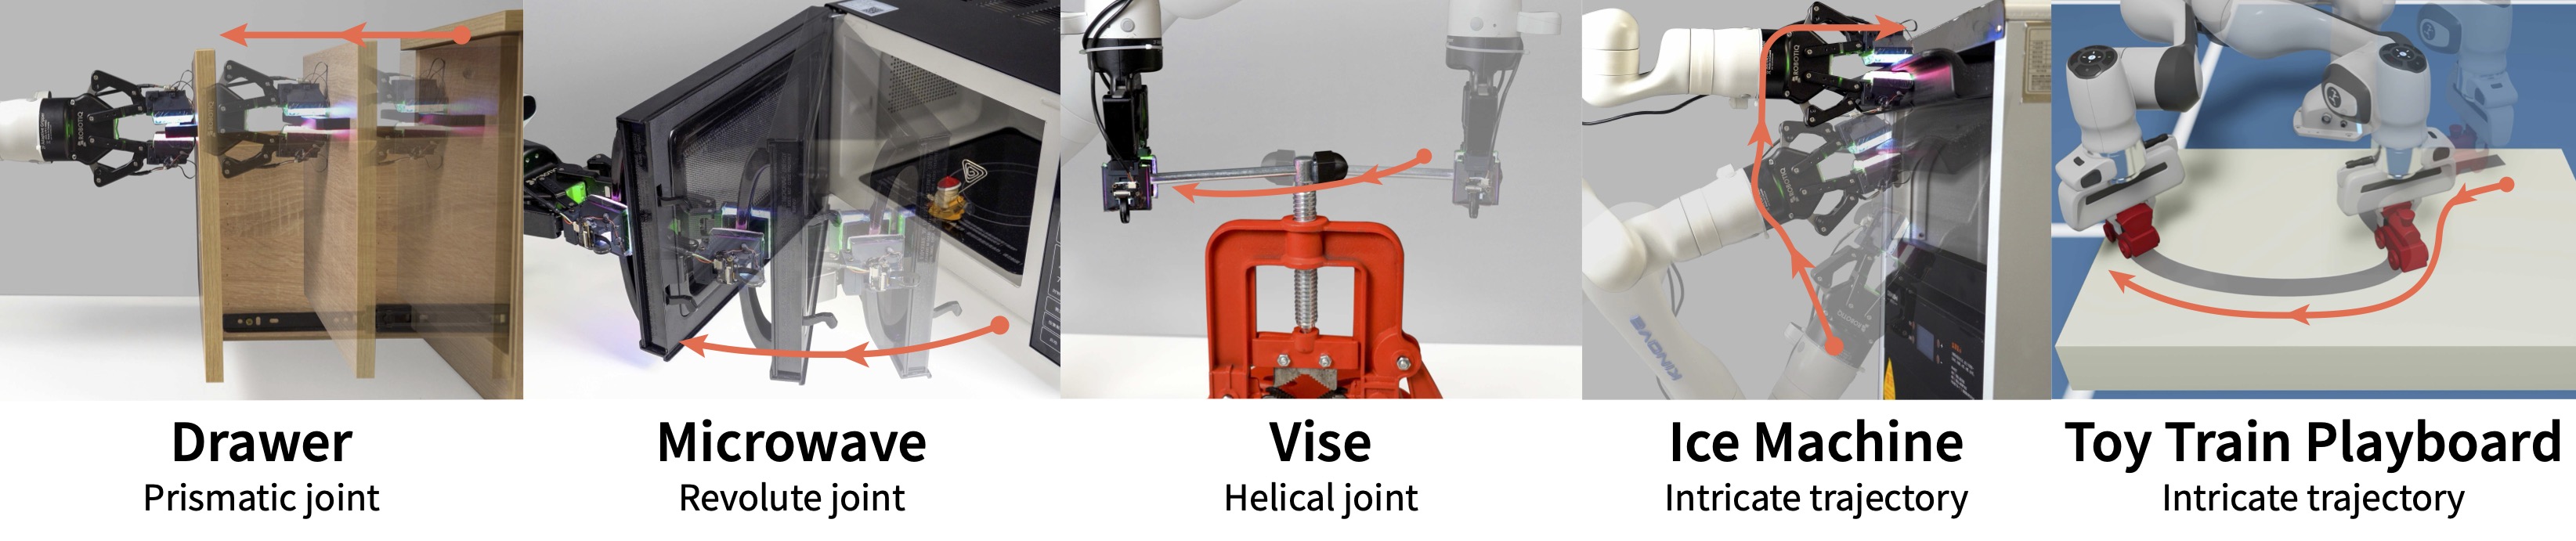

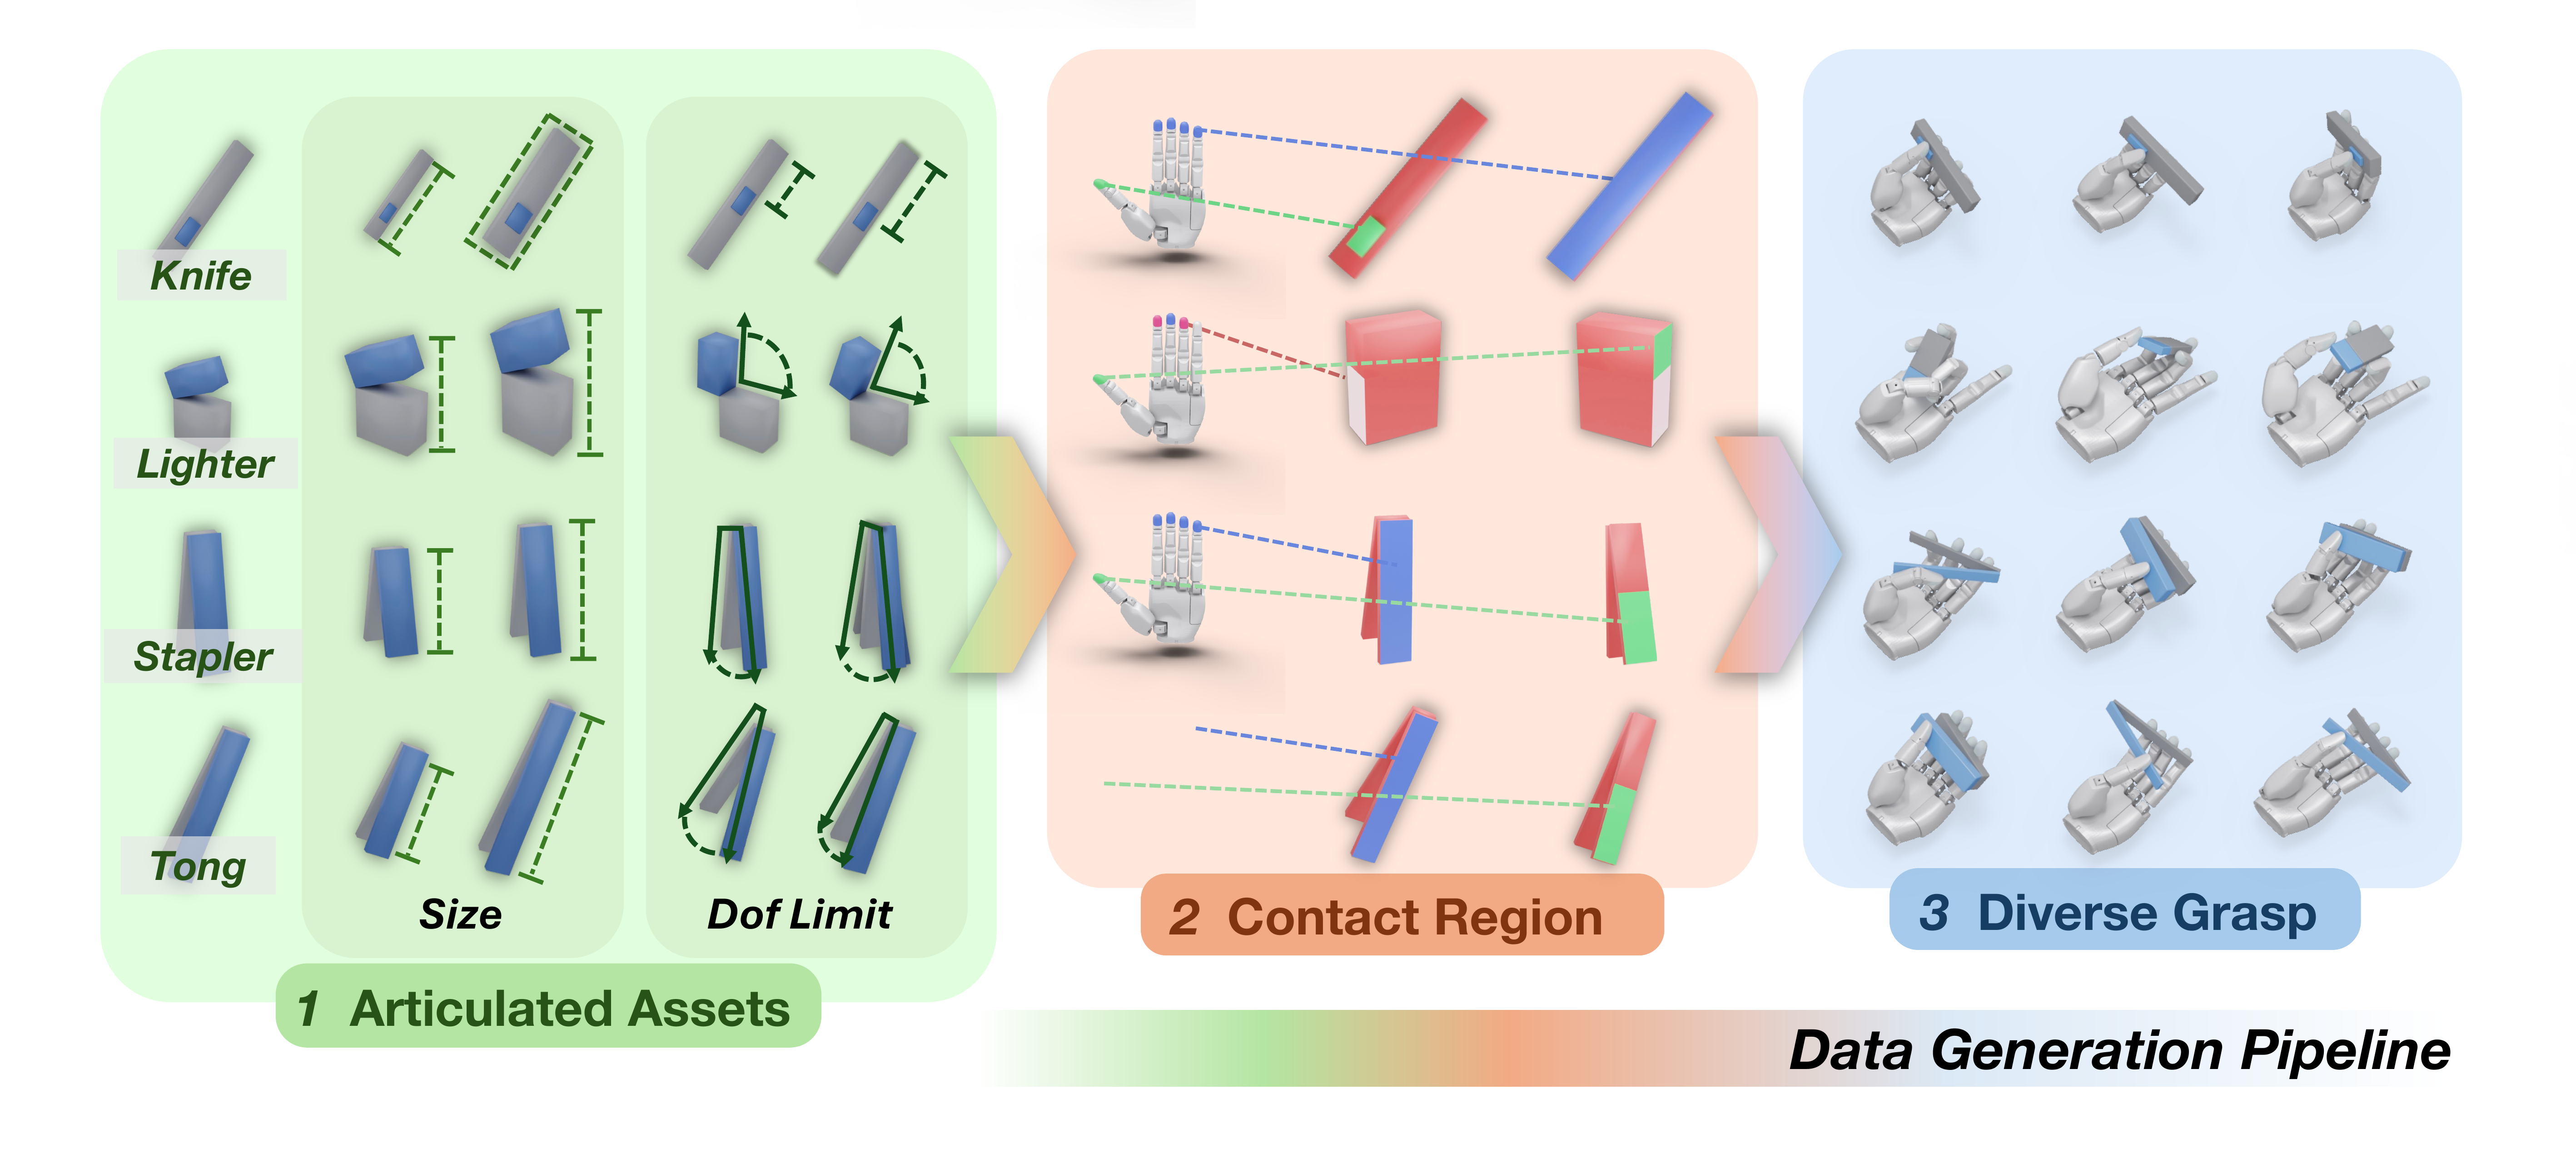
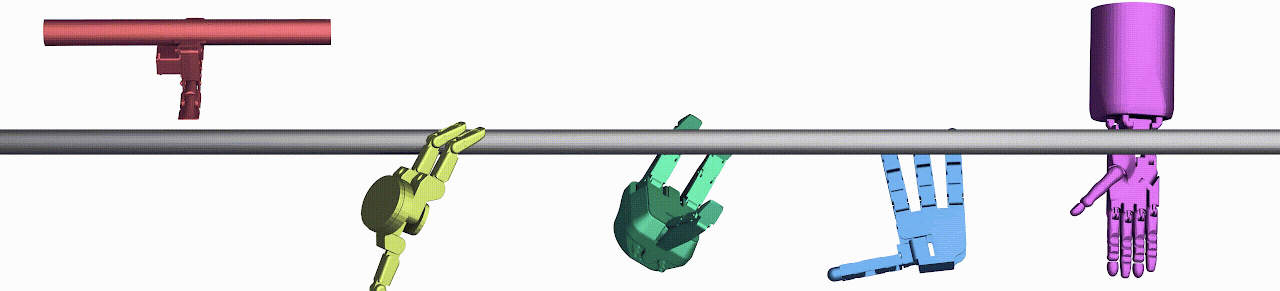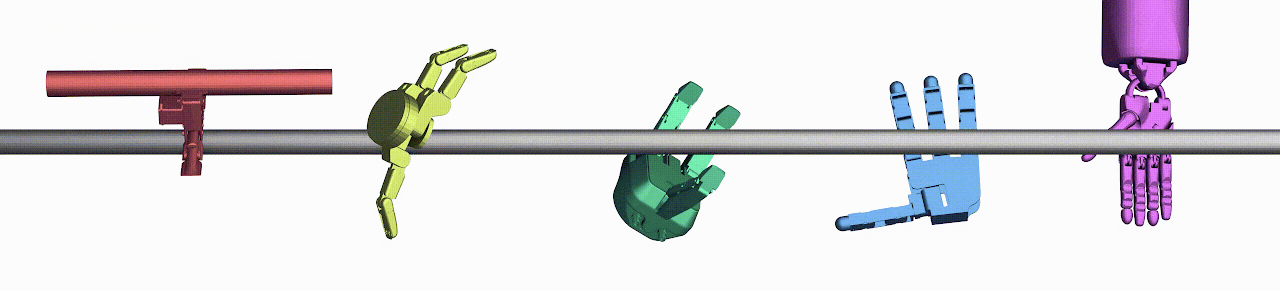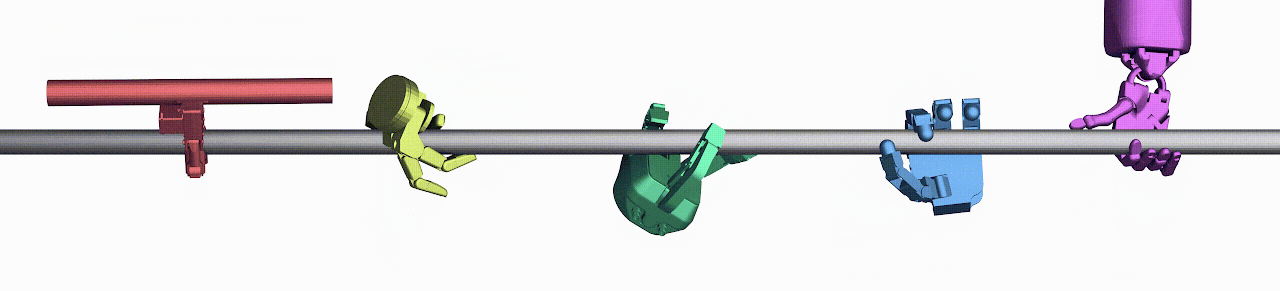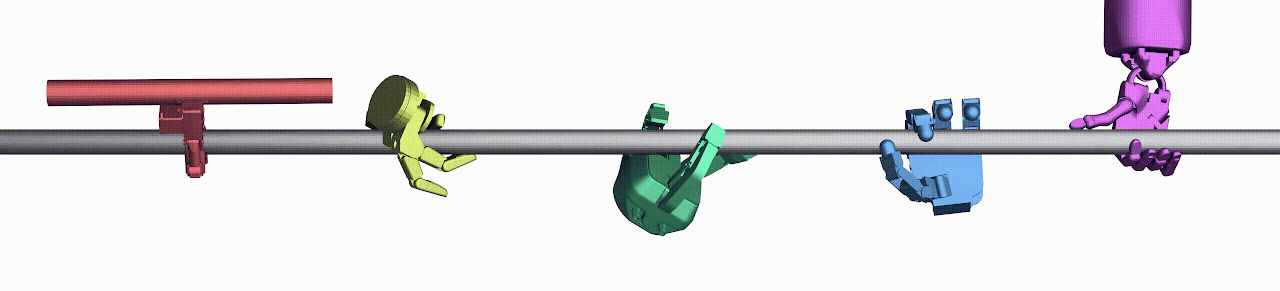
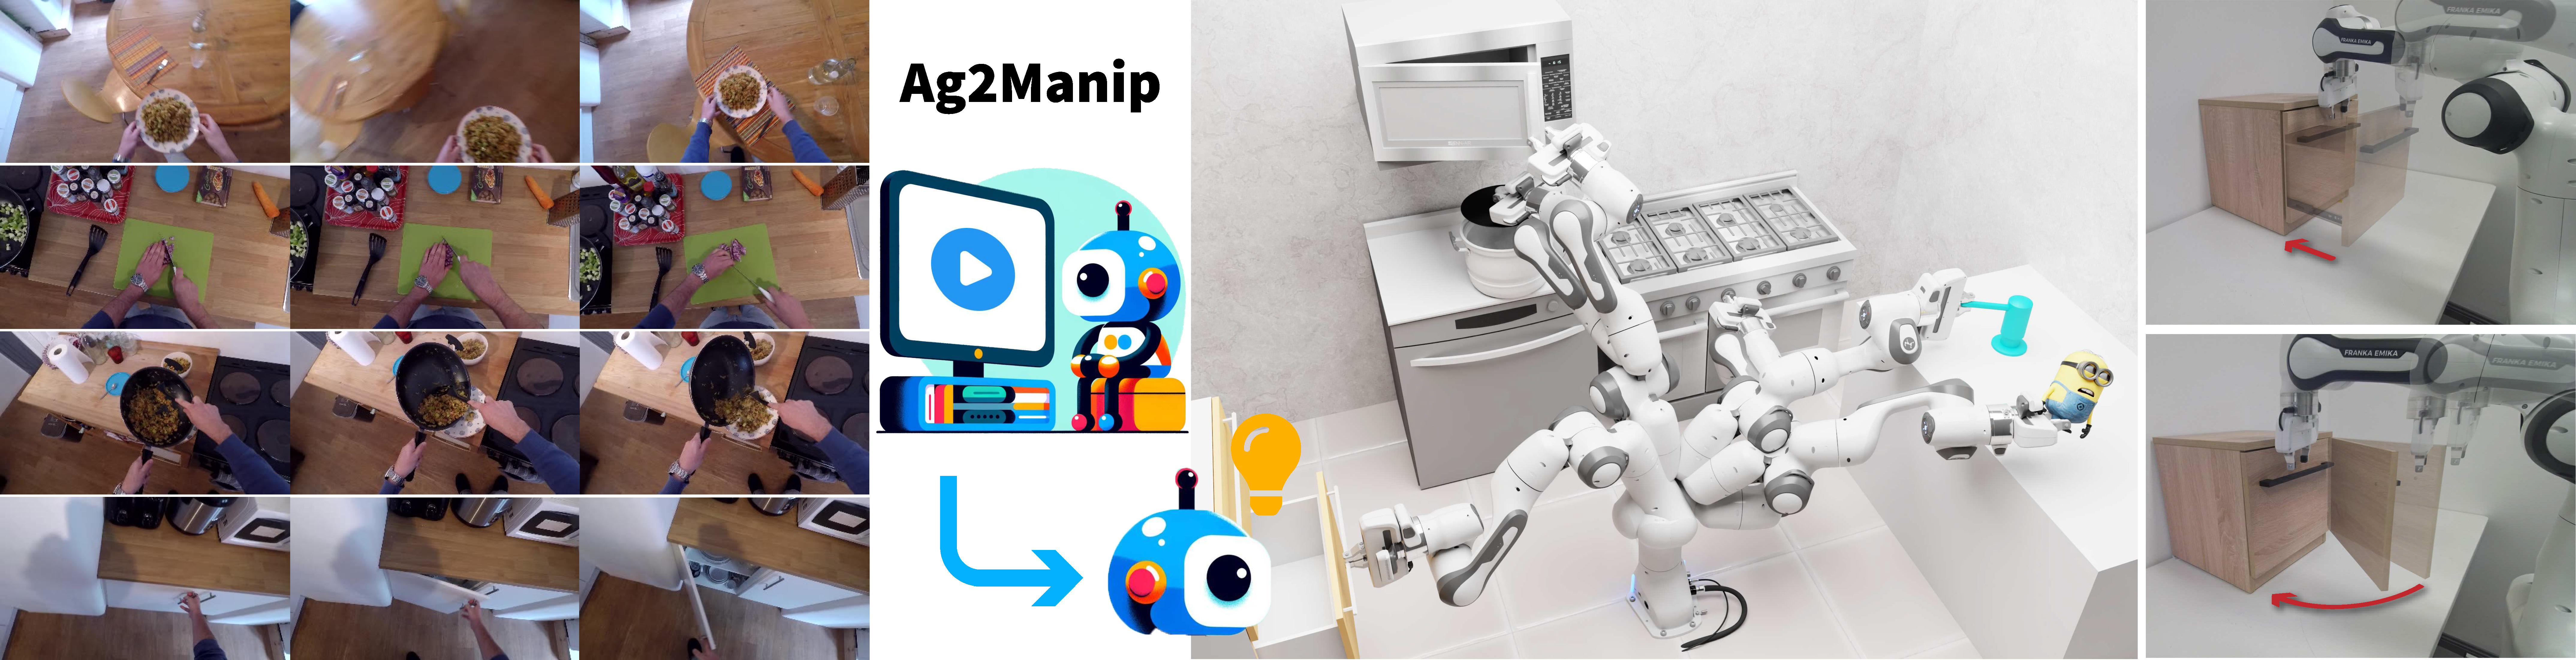
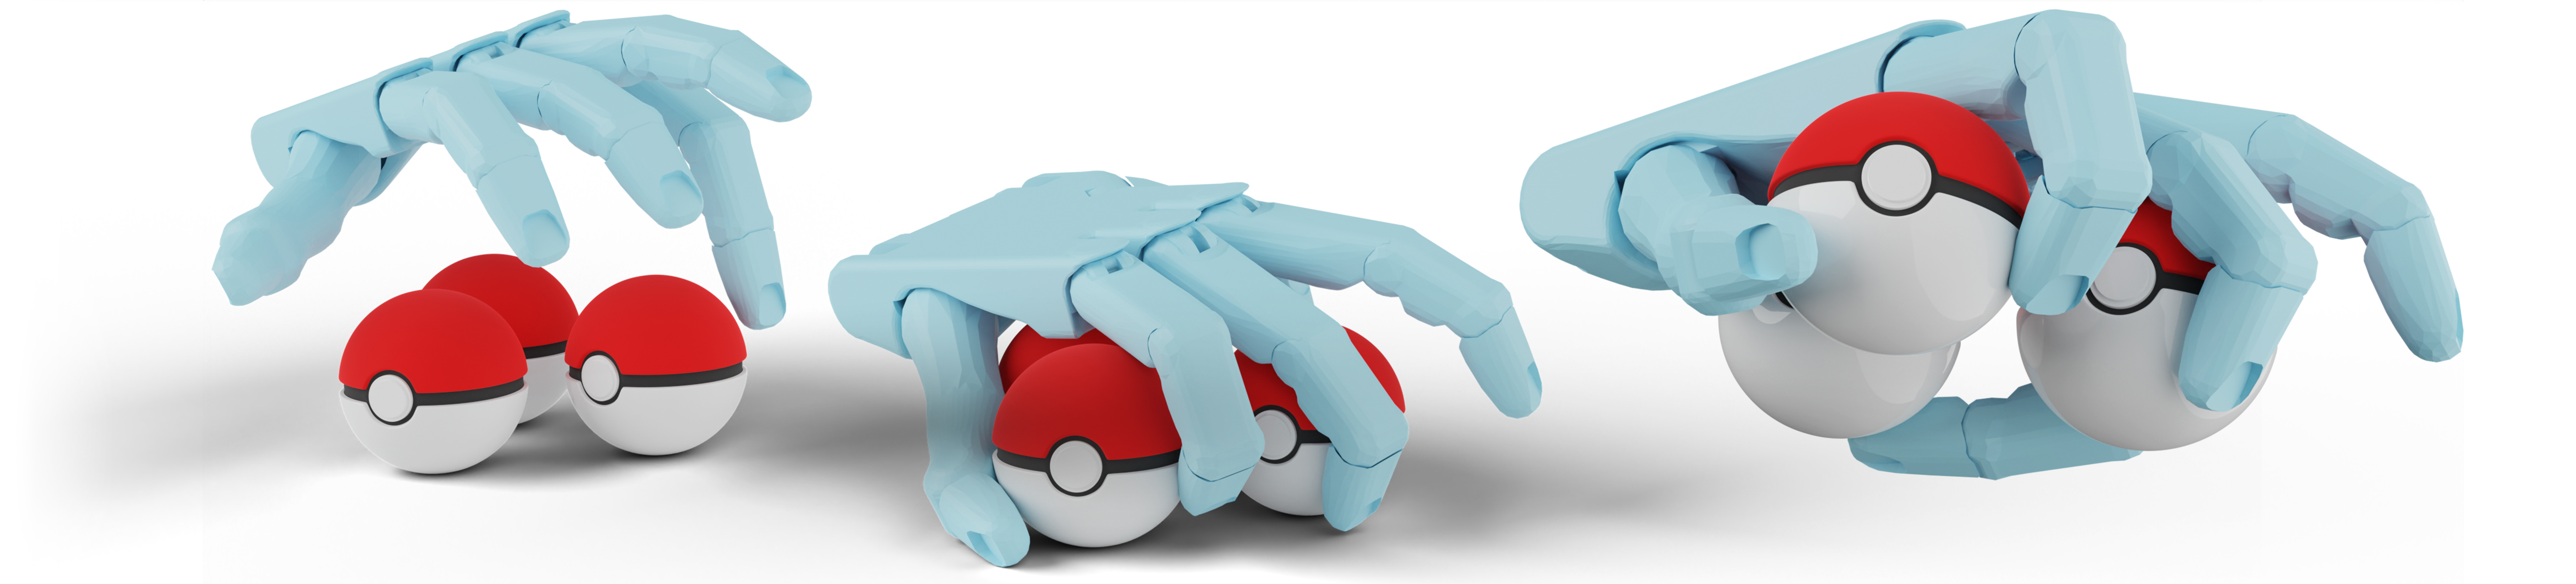
ArtManip: Category-Level In-Hand Manipulation of Articulated Objects
Learning dexterous policies of in-hand articulated objects that generalize across intra-class instances and initial grasps, with zero-shot sim2real capability.



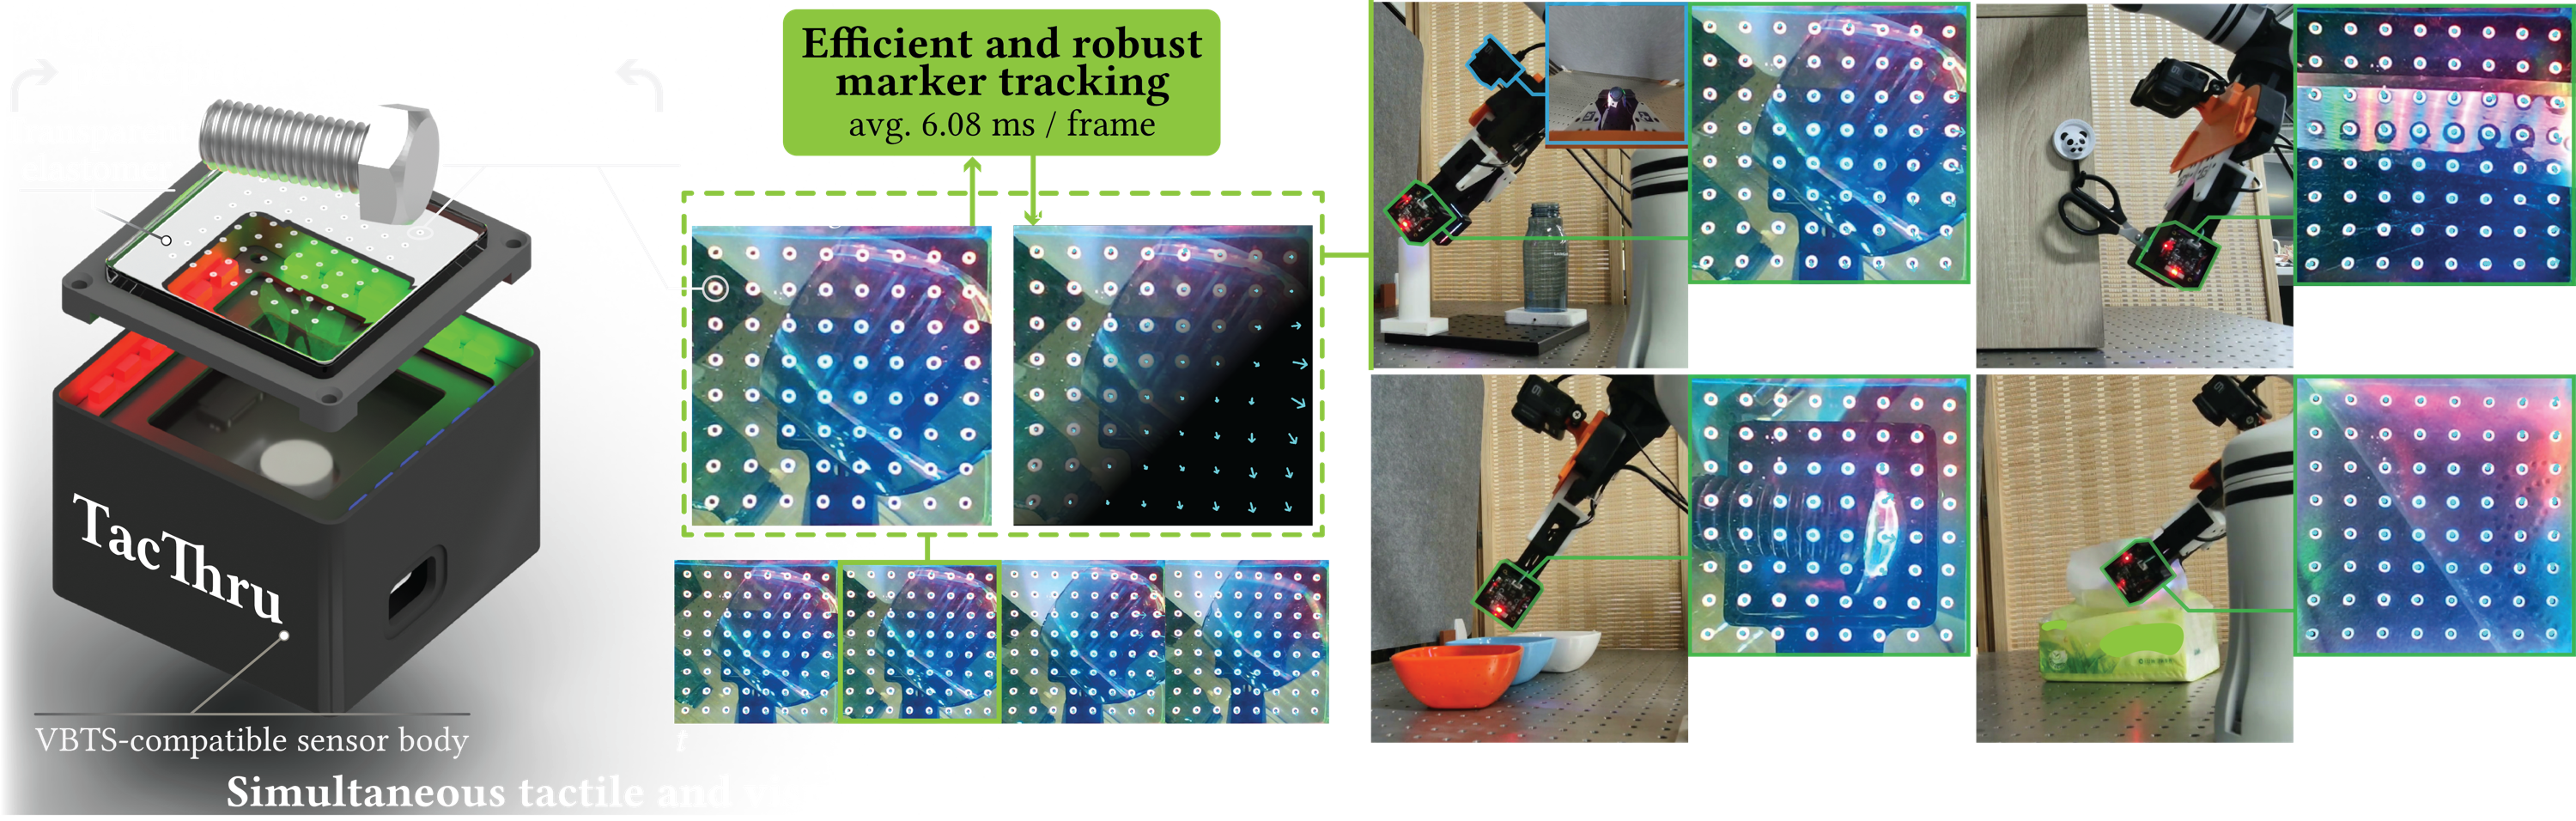
Simultaneous Tactile-Visual Perception for Learning Multimodal Robot Manipulation
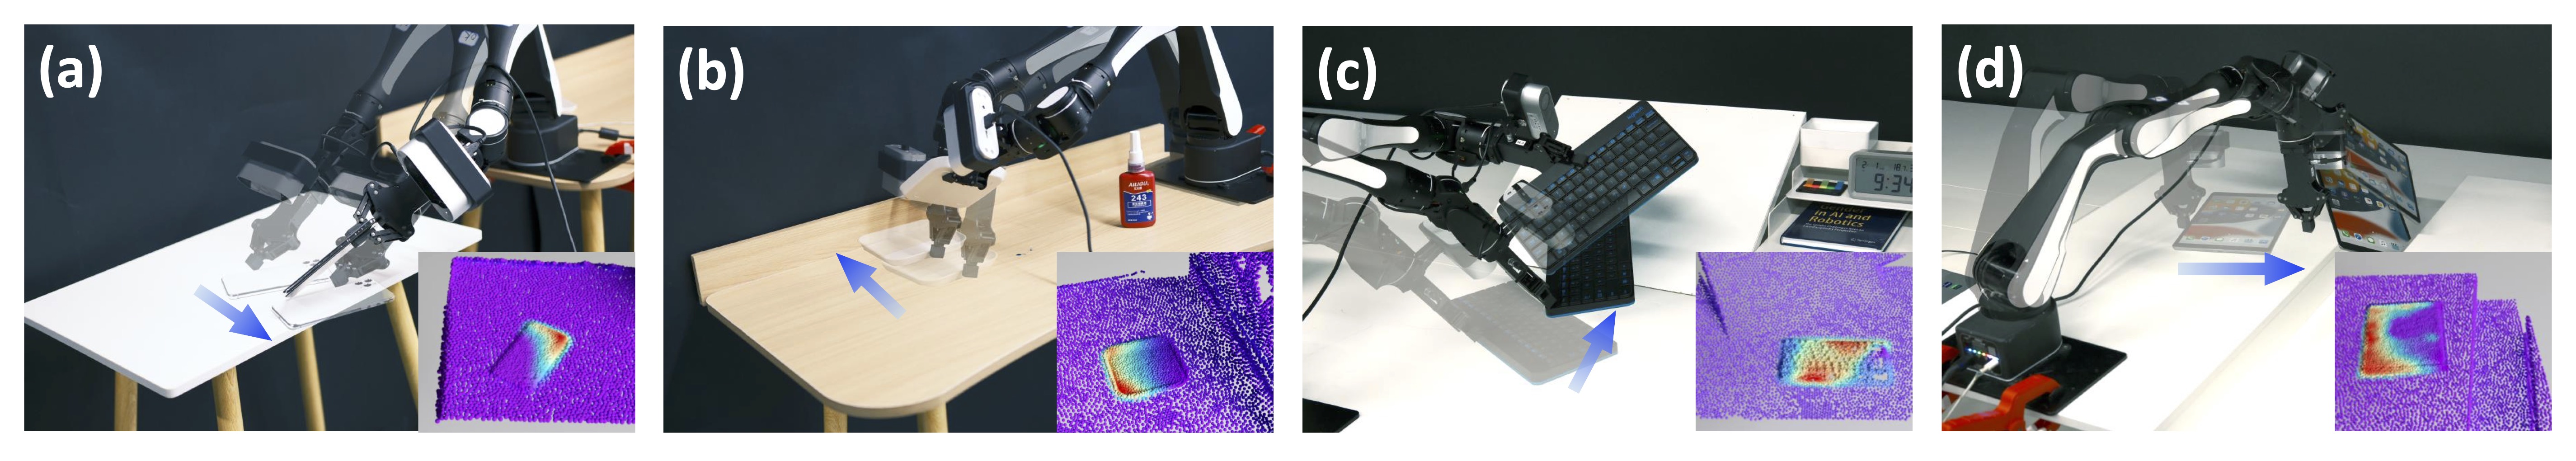
We propose TacThru, a see-through-skin (STS) sensor that provides simultaneous visual and tactile perception from the robot's fingertips.
 13 citations
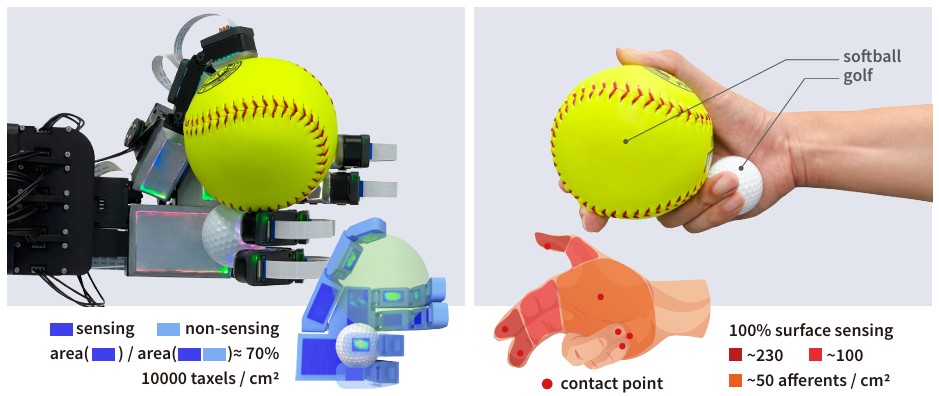
Embedding high-resolution touch across robotic hands enables adaptive human-like grasping
We design F-TAC Hand, a five-finger biomimetic hand featuring high-resolution tactile sensing across the hand. This design enables adaptive human-like grasping and unlocks more capabilities.
arXiv
Code
Website
Video
Science Robotics Editors' Choice
人民日报
新华网
中国新闻网
光明网
TechXplore
中国科技网
中国科学报
北大新闻网
北大新工科
北大AI院官微
北大AI院官网
 95 citations

Towards Human-level Dexterous Teleoperation
TeleDexter is a learned cerebellum for dexterous robot hands — a low-level co-tracking controller that maps operator intent into contact-rich execution in real time.
 0 citations